
October 1, 2026
Atlas learns to handle objects in its hand: new hand can pull a tool's trigger
Boston Dynamics is transferring skills for Atlas's new hand from simulation to the robot so it can learn physical tasks.
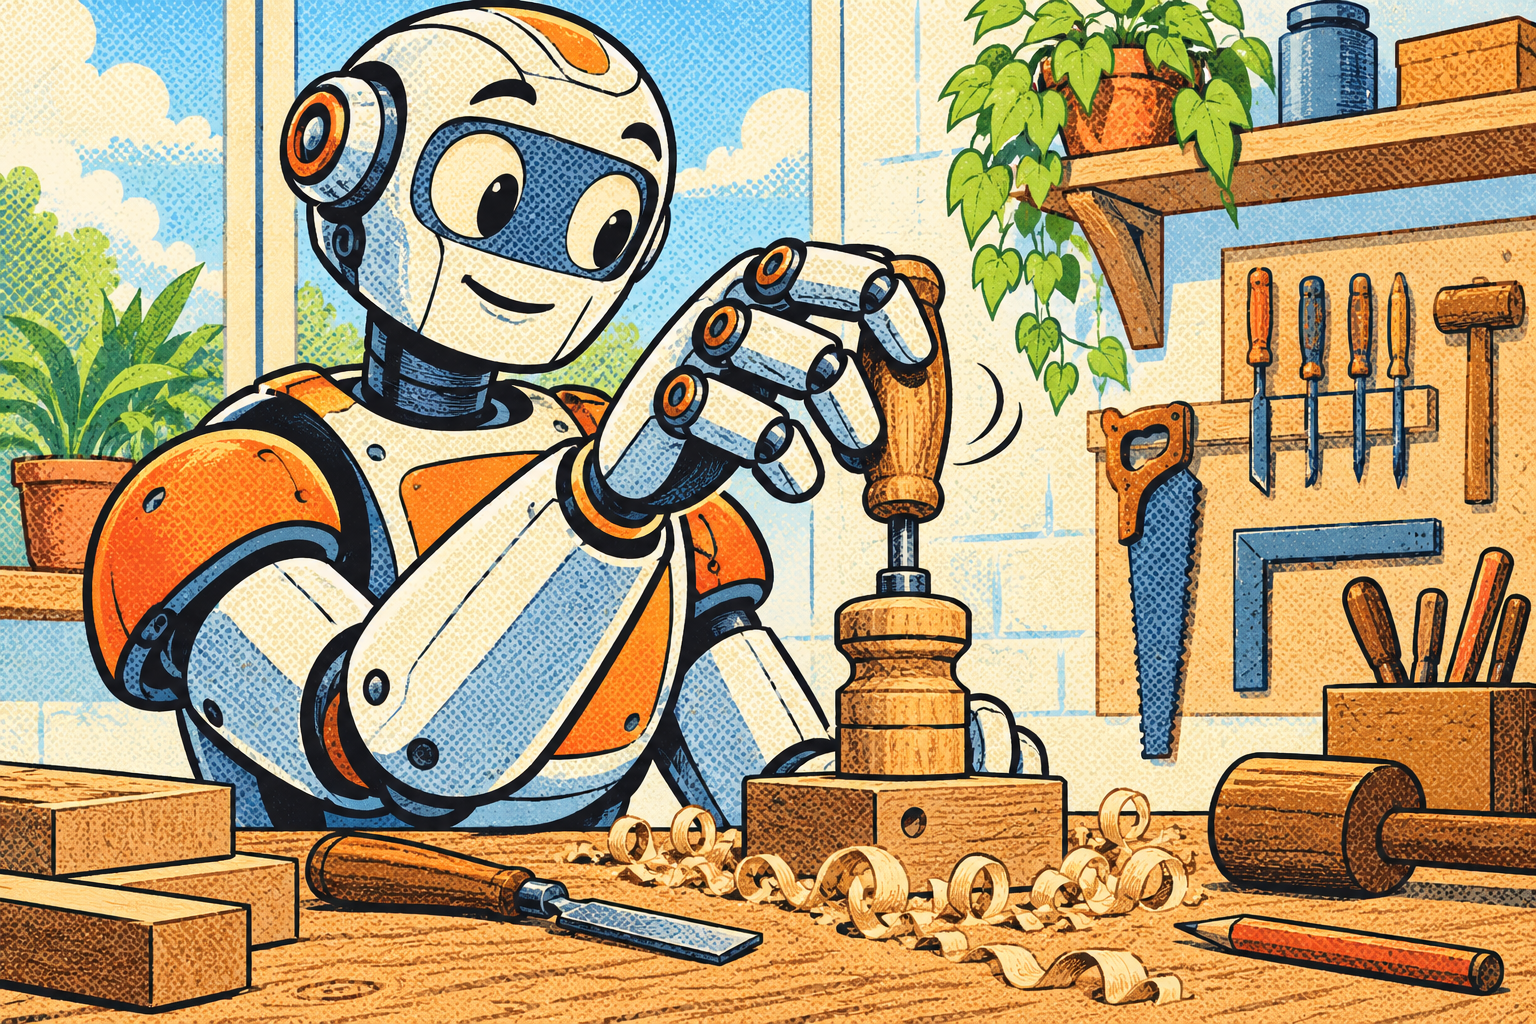
The new Atlas GR3 hand has 13 degrees of freedom, up from 7 in the GR2, according to Boston Dynamics as of Oct 1, 2026.
From grasping to working. The company designed the previous GR2 to grasp objects. The new GR3 can reorient an object in its hand, recover a slipping grip and pull a tool's trigger. Pressure sensors cover the fingertips and palm.
The GR3 has four fingers. Its opposable thumb has four degrees of freedom, while the other fingers have three each: the hand can independently bend and rotate their joints.
The team dropped the little finger after a one-day experiment. CTO Zack suggested that employees tape their little finger to their ring finger and spend a workday that way. After the experiment, the developers removed the little finger and three additional actuators from the design.
All GR3 joints use direct drive, and the team uses a single actuator type. The actuators are enclosed in housings, and no cables run through the joints.
Training in simulation. Boston Dynamics reports its first transfers of dynamic skills from a virtual environment to the physical hand. The team uses reinforcement learning and varies training conditions so the robot learns to perform the task under different conditions.
In simulation, the developers vary motor torque, surface friction and object geometry. They also introduce disturbances during the task. The robot receives feedback for this training only from the actuators themselves.
Boston Dynamics is accepting Atlas deployment inquiries through Atlas Contact, with the first deployments planned for a limited group of early customers.